Create: Schematic Compute
🎮 9 Programmable Blocks · 86 Node Types · Formula Syntax Highlighting & Autocomplete · Multiplayer Collaboration
九种可编程方块 · 86种节点 · 公式语法高亮与自动补全 · 多人实时协作
Drag, connect, and build logic — just like Unreal Engine Blueprints!
拖拽连接,构建逻辑 — 像虚幻引擎蓝图一样直观!
Created by StarryNight_Luo (y15173334444)



📖 Overview / 简介
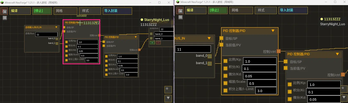
🇬🇧 Create: Schematic Compute is a Create mod addon that introduces 10 programmable blocks + 1 portable terminal with a visual node-based programming system. Instead of writing complex redstone circuits, simply drag and connect nodes to build logic — just like Unreal Engine Blueprints or Blender Geometry Nodes. Each computer runs at 20Hz (every game tick) for real-time control. All 10 blocks support real-time multiplayer collaborative editing with live cursor tracking and node lock protection. The FORMULA script editor features syntax highlighting (9 token colours), intelligent autocomplete (functions, variables, @output), real-time validation with error badges, and named constants (PI)/(E).
🇨🇳 机械动力:蓝图计算机 是一个机械动力附属模组,添加了十种可编程方块和一个便携终端,采用可视化节点图编程系统。无需搭建复杂红石电路,只需拖拽连接节点即可构建逻辑——就像虚幻引擎的蓝图系统或 Blender 的几何节点一样直观。每台设备拥有独立的节点图,以 20Hz(每游戏刻) 的频率运行,适合实时控制应用。全部 10 种方块支持多人实时协作编辑,带实时光标追踪和节点锁定保护。FORMULA 公式脚本编辑器 支持语法高亮(9 种词法颜色)、智能自动补全(函数、变量、@output)、实时校验与错误徽章、以及命名常量 (PI)/(E)。
🖥️ Blocks / 方块
🖥️ Holographic Monitor / 全息显示器
3D floating display / 3D 悬浮显示方块
| Feature / 功能 | Description / 说明 |
|---|---|
| 🖼️ Display Nodes / 显示节点 | TEXT, DATA, IMAGE, IMAGE_SEQUENCE / 文本、数值、图片、动画 |
| 🎨 16×16 Pixel Editor / 16×16像素编辑器 | Multi-frame animation + undo/redo / 多帧动画+撤销重做 |
| 📋 Layer Panel / 图层面板 | Drag-drop reorder + 24×24 thumbnails / 拖拽排序+缩略图预览 |
| 🎯 3D Positioning / 3D定位 | X/Y/Z + Roll/Pitch/Yaw freely adjustable / 自由调整位置和旋转 |
| 📡 Signal-Driven / 信号驱动 | IMAGE position/rotation via input signals / 通过输入信号驱位置旋转 |
| 📡 Redstone Input / 红石输入 | Read Redstone Link signals / 从红石链接网络读取信号 |
🖥️ Blueprint Computer / 蓝图计算机
Redstone Link controller / 红石链接控制器
| Feature / 功能 | Description / 说明 |
|---|---|
| 📡 Redstone I/O / 红石I/O | Read/Write Redstone Link network / 读写红石链接网络 |
| 🔗 Private Signal / 私有信号 | Named channel cross-computer communication / 命名通道跨计算机通信 |
| 🚌 Bus System / 总线系统 | BUS_IN/BUS_OUT multi-band data sharing / 多频段数据共享 |
| 📦 Encapsulation I/O / 封装导入导出 | File browser import/export .nbt files / 文件浏览器导入导出 |
⚡ Speed Proxy / 转速代理控制器
Speed Controller direct control / 转速直控
| Feature / 功能 | Description / 说明 |
|---|---|
| 🔄 Speed Control / 转速控制 | Set adjacent Speed Controller RPM (-256~256) / 设置相邻转速控制器RPM |
| 🔗 Private Signal / 私有信号输入 | Named channel cross-computer coordination / 命名通道跨计算机联动 |
⚙️ Programmable Transmission / 可编程变速器
In-line programmable gearbox / 轴上可编程变速
| Feature / 功能 | Description / 说明 |
|---|---|
| 🎚️ Target RPM / 目标转速 | Scroll-set absolute output RPM; graph TX_OUT node overrides while running / 滚轮设定绝对输出转速,图运行时由 TX_OUT 节点接管 |
| 🔀 Face-Relative Direction / 面相对转向 | Output CW/CCW follows the placed face, creative-motor style / 输出逆/顺随放置面(创造马达同款语义) |
| ↕️ 3-Axis Placement / 三向放置 | Horizontal or vertical in-line placement; wrench on side face rotates the axis / 水平/竖直线上放置,扳手点侧面换轴 |
| ⚙️ Bearing Visuals / 轴承动画 | Two independent shaft stubs: input follows network, output follows target / 两端独立轴头动画:输入随网络、输出随目标 |
| 🤝 Stress Network Member / 应力网络成员 | First-class driven member — no input power, no output / 官方应力网络一等成员,无输入动力则无输出 |
🔧 CNC Gearbox / 数控齿轮箱
Driven clutch + motion quota / 从动离合器 + 运动配额
| Feature / 功能 | Description / 说明 |
|---|---|
| 🔌 Clutch / 离合器 | Output face carries a shaft only while engaged; idle auto-disengages / 仅接合时输出面对外传轴,空闲自动分离 |
| 📜 Command Stack / 指令栈 | FIFO motion commands: rotate (degrees) / move (meters) / wait / FIFO 运动指令:旋转(度)/ 直线(米)/ 等待 |
| 🎯 Motion Quota / 运动配额 | Open-loop travel booking, fires a completion pulse at zero / 开环行程记账,配额归零自动打完成脉冲 |
| 🔄 Encoder / 编码器 | Rotary (degrees) + linear (meters) accumulation for graph readback / 旋转(度)+ 直线(米)累计供图读取 |
| ↕️ 3-Axis + Wrench / 三向 + 扳手 | Wrench on end face flips the input, side face rotates the axis / 扳手点端面翻转输入端、点侧面换轴 |
🔌 Program Computer / 编程计算机
Sequential logic / 时序逻辑专用机
| Feature / 功能 | Description / 说明 |
|---|---|
| 📡 Redstone I/O / 红石I/O | Redstone Link network communication / 红石链接网络通信 |
| 🔗 Private Signal / 私有信号 | PRIVATE_IN/PRIVATE_OUT named channel I/O / 命名通道I/O |
| ⏱️ Sequential Nodes / 时序节点 | Delay/Latch/T Flip-Flop/Gate/Pulse Extend/Loop/Fuse/Accumulator/Integrator / 延时/锁存器/T触发器/闸门/脉冲延长/循环/保险/累计器/连续积分器 |
🪑 Control Seat / 控制座椅
Sit-able controller / 可乘坐控制器
| Feature / 功能 | Description / 说明 |
|---|---|
| ⌨️ 58 Key Bindings / 58键绑定 | Click-to-bind UI / 点击绑定 |
| 🖱️ Dual Mode / 双模式 | Joystick (mouse delta) / View Angle (rotation difference) / 摇杆/视角差 |
| 🎮 Gamepad / 手柄 | Dual stick + 15 buttons + analog triggers LT/RT / 双摇杆+15键+模拟扳机 |
| 🔄 Sable Compatible / Sable兼容 | Two camera modes (FIXED / VIEW_DIFFERENCE), world-orientation tracking via quaternion / 双相机模式,四元数世界朝向追踪 |
| 🚪 Controls / 操作 | Right-click sit / Shift+Right-click editor / ~ dismount / TAB mode / ESC release |
📐 Attitude Sensor / 姿态传感器
Physics structure orientation / 物理结构姿态读取
| Feature / 功能 | Description / 说明 |
|---|---|
| 📐 ATTITUDE / 姿态 | Block world-space pitch and roll (facing × sub-level rotation) / 方块自身世界姿态俯仰与横滚(朝向 × 子世界旋转) |
| 🧭 FORWARD / 前方朝向 | World-space forward yaw/pitch / 结构世界空间朝向 |
| ⚡ ACCELERATION / 加速度 | Block-local X/Y/Z acceleration (structure motion in block axes) / 方块本地加速度(结构运动按方块朝向分解) |
| 🚀 VELOCITY / 速度 | Block-local velocity ×2 m/s (structure motion in block axes) / 方块本地速度(结构运动按方块朝向分解) |
| 🔄 POSE_CONVERT / 姿态换算 | Coordinate conversion / 坐标系转换 |
📡 3D Holographic Radar / 3D全息显示雷达
Real-time scanner / 实时实体扫描器
| Feature / 功能 | Description / 说明 |
|---|---|
| 📡 Scan Range / 扫描范围 | 1-128 blocks configurable / 1-128格可配置 |
| 🎯 Target Lock / 目标锁定 | Manual right-click + auto closest / 手动右键锁定+自动最近 |
| 🖥️ Display Style / 显示风格 | Classic XYZ axes / Holographic (white cube + blue plane) / 经典/全息 |
| 📊 TARGET_OUT | Output X/Y/Z/entity ID/distance / 输出坐标/实体ID/距离 |
| 🔍 Filters / 过滤 | Show/hide players, mobs, Sable structures / 独立显示玩家/生物/Sable |
📱 Portable Terminal / 便携终端
Handheld remote editor / 手持远程编辑器
| Feature / 功能 | Description / 说明 |
|---|---|
| 📡 Device Scan / 设备扫描 | Scan 1-128 blocks for programmable blocks / 扫描1-128格可编程方块 |
| ✏️ One-Click Edit / 一键编辑 | Open native GUI instantly / 即时打开原生GUI |
| 📦 All 10 Blocks / 全10方块 | Monitor, Blueprint, Program, Radar, Seat, Sensor, SpeedProxy, Transmission, CNC Gearbox, Kinetic Gauge |
| 🔄 Sable Compatible / Sable兼容 | Sub-level scanning with rotation correction / 子世界扫描+旋转修正 |
🎛️ Kinetic Gauge / 动力传感器
In-line kinetic readout + graph host / 轴上传动读数 + 节点图宿主
| Feature / 功能 | Description / 说明 |
|---|---|
| 📊 Built-in Readout / 内置读数 | Speed digits + stress bar (green→yellow→red, overload blink) + percentage, painted on the panel / 转速数字 + 应力条(绿→黄→红,超载闪烁)+ 百分比,直接画在面板上 |
| 🖥️ Graph Display / 图形接管 | DATA/TEXT nodes in its graph take over the panel (server-authoritative eval snapshot) / 图里的 DATA/TEXT 节点接管面板(服务端求值快照权威) |
| 📈 STRESS / 应力状态 | 4 outputs — ratio (0-1, >1 overloaded), used (SU), unused (0-1), left (SU) / 四个输出——占比、已用(SU)、未用、剩余(SU) |
| ⚡ RPM / 转速 | 1 output — signed network speed (0 unpowered/overloaded) / 一个输出——带符号网络转速(无动力/过载为 0) |
| 🔄 3-Axis Placement / 三轴放置 | Floor/ceiling placement points the display at the player (all 4 yaws, vertical state placeable directly); wall placement uses the clicked face; auto-aligns to a shaft-bearing face / 贴地贴顶正对玩家(四向可选,竖置可直接放出);贴墙用点击面;贴轴自动对齐 |
| 🔧 Wrench / 扳手 | Shaft end face + display side: cycle the panel 90° around the shaft (shaft untouched); the other two faces: rigid rotate (shaft re-points) / 轴端面+显示面:面板绕轴 90° 循环(轴不动);其余两面:整表旋转(轴换向) |
| ⚙️ Shaft Pass-Through / 贯通传轴 | Passes rotation along its own axis and reads the network it sits in / 自身沿旋转轴贯通传轴,并读取所在动力网络的转速与应力 |
| 🧩 Two Model Variants / 双模型变体 | Lectern panel for horizontal shafts, flat panel for vertical shafts; text always upright / 水平轴用讲台面板,竖直轴用平板屏,文字永远直立 |
👥 Multiplayer Collaboration / 多人协作(v1.2.4+)
Real-time collaborative graph editing for all 7 block types. Multiple players can edit the same graph simultaneously. 全部 7 种方块支持多人实时协作编辑同一节点图。
| Feature / 功能 | Description / 说明 |
|---|---|
| 🖱️ Live Cursor Tracking / 实时光标 | Colored crosshairs with player names / 彩色十字准星+玩家名 |
| 📦 Remote Drag / 远程拖拽 | Smooth animated node movement / 平滑动画节点移动 |
| 🔗 Wire Preview / 连线预览 | Live bezier curve while dragging / 实时贝塞尔曲线预览 |
| 👤 Player List / 玩家列表 | Right-side vertical list, host highlighted / 右侧竖向列表,房主高亮 |
| 🔒 Node Lock / 节点锁定 | IMAGE nodes protected during pixel edit / 像素编辑时锁定IMAGE节点 |
| 🚪 Auto-Close / 自动关闭 | UI closes when block destroyed / 方块破坏时自动关闭 |
| ⚡ Join/Leave / 加入离开 | Appear immediately on open, disappear on close / 打开即现,关闭即消 |
📝 Formula Script Node / 公式脚本节点
Multi-line script editor (v1.2.0+) — assignments, control flow, vec3, named outputs, comments, line continuation.
多行脚本编辑器 — 支持赋值、控制流、vec3、命名输出、注释、续行。完整语法见 docs/formula-syntax-manual.md。
🧮 Syntax Overview / 语法速览
赋值与输入引脚 / Assignments & input pins — any name assigned anywhere is an internal variable; every other name that is read becomes an input pin. 任何处被赋值的名字是内部变量,其余被读取的名字成为输入引脚:
x = a + 1        -- x 内部变量 / internal; a 成为输入引脚 / input pin
@output x
→ 1 input pin + 1 output / 1 输入 + 1 输出
控制流 / Control flow — repeat / while / if / else / break / continue:
acc = 0
repeat 100 { acc = acc + 1 }
if (acc > 50) { acc = 0 } else { acc = 1 }
@output acc
比较与逻辑 / Comparison & logic — < > <= >= are exact; ==/!= use a 1e-6 tolerance; && || ! judge truthiness as !=0. < > <= >= 精确;==/!= 1e-6 容差;&& || ! 以 !=0 判真。
vec3 与向量函数 / vec3 & vector functions:
v = vec3(3, 4, 0)
@output length(v)     -- 5
@output yaw(v)        -- 角度制,与 DIRECTION 节点一致 / degrees, mirrors DIRECTION
@output v             -- vec3 自动展开为 v.x/v.y/v.z 三个输出引脚 / expands into 3 scalar pins
Vector functions: vec3 length normalize dot cross dist yaw pitch; component access v.x/y/z. 向量函数:vec3 length normalize dot cross dist yaw pitch;分量访问 v.x/y/z。
函数表 / Functions(角度均按度 / trig in degrees):
15 个标量函数 / 15 scalar functions — sin cos tan asin acos atan2 sinh cosh sqrt ln log exp sec csc cot
7 个向量函数 / 7 vector functions — vec3 length normalize dot cross dist yaw pitch
中文输入即转 / CJK input converts live — ()→()、×→*、≥→>=,full-width letters/digits/spaces convert to half-width as you type. ()→()、×→*、≥→>=、全角字母/数字/空格即输即转半角。
预算池 / Budget pool — loop-heavy scripts spread across ticks: a thin progress bar below the node shows solve progress; outputs freeze during the spread and update only on completion (emit-on-done); the warm edit-panel toggle controls whether an input change keeps iterating or strictly freezes. 循环重负载脚本跨 tick 分摊:节点下方进度条显示解算进度,spread 期间输出冻结、完成才更新(emit-on-done);warm 编辑区开关控制输入变更时继续迭代还是严格冻结。典型应用见下方火控弹道解算示例。
🎯 火控弹道解算示例 / Fire-Control Ballistic Solver Example
Newton-iteration aim solver ported from a Python reference (CreateBigCannons ballistic model: semi-implicit Euler dt=1/20, linear/quadratic drag), verified against four reference scenarios.
牛顿迭代弹道反解,移植自 Python 参考实现(CreateBigCannons 弹道模型:半隐式欧拉 dt=1/20、线性/二次阻力),四组场景对拍通过。
Full paste-ready script: docs/examples/ballistic_solver.formula — ~600k interpreter iterations per solve, spread across ticks by the budget pool with a progress bar.
完整可粘贴脚本:docs/examples/ballistic_solver.formula(约 60 万次迭代,由预算池跨 tick 分摊、带进度条)。
-- 输入:mx,my,mz 炮口 / tx,ty,tz 目标 / v0 初速 / g 重力(正) / fd 阻力系数 / qd 二次阻力 / den 密度
-- inputs: mx,my,mz muzzle / tx,ty,tz target / v0 speed / g gravity(+) / fd drag / qd quadratic drag / den density
-- 输出:ay 射向角[0,360) / ap 射角 / hit 可达 / vx0,vy0,vz0 初速向量
-- outputs: ay aim yaw [0,360) / ap aim pitch / hit reachable / vx0,vy0,vz0 velocity vector
ay = atan2(tx - mx, 0 - (tz - mz))
if (ay < 0) ay = ay + 360
cy = cos(ay)
sy = sin(ay)
-- 俯仰粗扫描(361 点)+ 轨迹模拟(半隐式欧拉 dt=1/20,阻力/重力积分,记录最近距离)
-- pitch coarse scan (361 points) + trajectory simulation (semi-implicit Euler dt=1/20, drag/gravity integration, track closest distance)
p = -89.899
bestd = 1000000
repeat 361 {
  vx = v0 * cos(p) * sy
  vy = v0 * sin(p)
  vz = v0 * cos(p) * (0 - cy)
  -- ... 1200 步轨迹模拟(完整脚本见上方链接) ... / 1200-step simulation (full script linked above)
  p = p + 0.49944
}
-- 牛顿迭代精化(≤50 轮,中心差分,阻尼 0.5) / Newton refinement (≤50 rounds, central difference, damping 0.5)
@output ay
@output ap
@output hit
→ 11 inputs + 6 outputs / 11输入 + 6输出
🎨 Syntax Highlighting / 语法高亮
Real-time colour-coded editing with 9 token categories. 9 种词法分类的实时彩色标注。
| Token Type / 词法类型 | Colour / 颜色 | Examples / 示例 |
|---|---|---|
| Functions / 函数 | 🟡 Yellow / 黄色 | sin, cos, sqrt, exp |
| Constants / 常量 | 🩷 Pink / 粉色 | (PI), (E) — 仅分组括号内视为字面量 |
| Identifiers / 标识符 | 🩵 Light Cyan / 浅青 | x, speed, myVar |
| Numbers / 数字 | 🟠 Orange / 橙色 | 3.14, 42, 0.5 |
| Operators / 运算符 | ⬜ Grey / 灰色 | +, -, *, /, ^, % |
| Parens / 括号 | ⬜ Grey / 灰色 | (, ) |
| Comments / 注释 | 🟢 Green / 绿色 | -- this is a comment |
| @output / 输出 | 🟣 Purple / 紫色 | @output |
| Assignment / 赋值 | 🟣 Purple / 紫色 | = |
| Unknown / 未知 | 🔴 Red / 红色 | Invalid characters / 非法字符 |
🔍 Autocomplete / 自动补全
Type to trigger suggestions near the caret, rendered above all pins. 输入即触发,候选框显示在光标下方、所有引脚上方。
| Trigger / 触发方式 | Behaviour / 行为 |
|---|---|
| Type identifier char / 输入标识符字符 | Filtered dropdown: functions, constants, current variables / 过滤候选:函数、常量、当前变量 |
Type @ / 输入 @ |
Immediately suggests @output / 立即建议 @output |
Tab / Enter |
Accept selected candidate / 接受选中候选项 |
↑ ↓ |
Navigate candidates / 导航候选项 |
Esc / any other key |
Close popup / 关闭候选框 |
| Click candidate / 点击候选项 | Accept and insert / 接受并插入 |
| Zoom-aware / 缩放感知 | Popup scales with graph zoom level / 候选框随图缩放 |
✅ Real-Time Validation / 实时校验
Issues shown as red ⚠ badge on the node title bar. Hover the badge to see details. 错误以红色 ⚠ 徽章显示在节点标题栏,悬停查看详情。
| Check / 校验项 | Type / 类型 |
|---|---|
| Bracket matching / 括号匹配 | Error / 错误 |
| Unknown function / 未知函数 | Error / 错误 |
| Function arity / 函数参数数量不符 | Error / 错误 |
| Invalid assignment / 无效赋值 | Error / 错误 |
| Duplicate output names / 重复输出名 | Warning / 警告 |
| @output invalid start / @output 起始非法 | Warning / 警告(表达式输出合法,如 @output length(v)) |
| Red border on MLE / 输入框红色边框 | Visual feedback / 视觉反馈 |
📐 Named Constants / 命名常量
(PI) and (E) in grouping parentheses are literal constants (π ≈ 3.14159, e ≈ 2.71828).
Bare PI / E or PI / E inside function calls like sin(PI) are treated as variable references (create input pins).
(PI) 和 (E) 在分组括号内视为字面常量。裸 PI/E 或函数调用内的 sin(PI) 视为变量(创建输入引脚)。
-- (PI) = literal π, not a variable / 字面量π,不是变量
-- sin(PI) = PI is a variable input / PI 是变量输入
result = (PI) + sin(PI)
@output result
→ 1 input pin (PI) + 1 output / 1 输入引脚 + 1 输出
🚌 BUS System / BUS 总线系统
Global named-channel communication across computers. Like publish-subscribe message bus. 全局命名通道跨计算机通信系统,类似发布-订阅消息总线。
| Feature / 功能 | Description / 说明 |
|---|---|
| 🚌 BUS_OUT / 总线输出 | Write values to named channel with bands / 写入命名通道+频段 |
| 🚌 BUS_IN / 总线输入 | Read band values from channel / 从通道读取频段值 |
| 📋 Band System / 频段 | Named sub-fields per channel / 每通道命名字段 |
| 🔢 Ref Counting / 引用计数 | Auto-cleanup when no BUS_OUT references / 无引用时自动清理 |
| ⚠️ Conflict Detection / 冲突检测 | Reject duplicate channel names / 拒绝重名通道 |
🧩 Node Reference / 节点参考(95 种)
📦 Values / 数值
| Node / 节点 | Description / 说明 |
|---|---|
| Constant / 常量 | Outputs constant value / 输出常量值 |
| Redstone Input / 红石输入 | Reads from Redstone Link / 从红石链接网络读取 |
| Private Signal Input / 私有信号输入 | Reads float from named channel / 从命名通道读取浮点数 |
| Bus Input / 总线输入 | Reads bus channel bands / 从总线通道读取频段值 |
📊 Kinetic Readings / 动力读数 (Kinetic Gauge / Transmission / CNC Gearbox)
| Node / 节点 | Description / 说明 |
|---|---|
| Stress Status / 应力状态 | Kinetic network stress, 4 outputs: ratio (0-1, >1 overloaded), used (SU), unused (0-1), left (SU); all 0 with no network or zero capacity / 动力网络应力,四个输出:占比(0-1,超载 >1)、已用(SU)、未用(0-1)、剩余(SU);无网络/零容量全 0 |
| Speed (RPM) / 转速 | Network rotation speed, signed (negative = reversed), 0 when unpowered/overloaded / 网络转速,带符号(负=反转),无动力/过载为 0 |
🔢 Basic Math / 基础运算
| Node / 节点 | Description / 说明 |
|---|---|
| Add / 加法 | A + B |
| Subtract / 减法 | A - B |
| Multiply / 乘法 | A × B |
| Divide / 除法 | A ÷ B (0 if B=0) |
| Modulo / 模运算 | A % B |
| Power / 次幂 | A ^ B |
| Root / 次方根 | B-th root of A |
| Absolute Value / 绝对值 | |input| |
| Ceil / 向上取整 | Round up |
| Floor / 向下取整 | Round down |
📐 Advanced Math / 高级运算
| Node / 节点 | Description / 说明 |
|---|---|
| Formula / 公式 | Multi-line script editor / 多行脚本编辑器 |
| Round / 保留N位小数 | Round to N decimals / 保留N位小数 |
| Comparison Router / 比较路由 | |A-B| smart routing / 智能信号分流 |
| Pose Convert / 姿态换算 | Pitch/Yaw/Roll coordinate conversion / 姿态角转换 |
| Split / 分割 | Positive/negative signal split / 正负信号分离 |
Trig / 三角函数(度): Sine · Cosine · Tangent · Arc Sine · Arc Cosine · Arc Tangent 2 · Hyperbolic Sine · Hyperbolic Cosine
Other / 其他: Square Root · Natural Log · Base-10 Log · Exponential · Secant · Cosecant · Cotangent · Angle Unwrap · Direction (3-in 3-out)
🧠 Logic / 逻辑
| Node / 节点 | Description / 说明 |
|---|---|
| Greater Than / 大于 | A > B |
| Less Than / 小于 | A < B |
| Greater or Equal / 大于等于 | A ≥ B |
| Less or Equal / 小于等于 | A ≤ B |
| Equals / 等于 | A = B |
| OR Gate / 或门 | A > 0.5 or B > 0.5 |
| Bool / 布尔 | Boolean with invert toggle / 布尔(可反转) |
| Gate / 闸门 | Signal gate with Set/Reset/Toggle / 信号门 |
| Relay A / 继电器A | SPDT relay — contact false→A, contact true→B / 双掷继电器 |
| Relay B / 继电器B | SPST relay — out = contact ? B : A / 单掷合并继电器 |
🎛️ Control / 控制
| Node / 节点 | Description / 说明 |
|---|---|
| PID Controller / PID控制器 | SP/PV PID (scalable output, anti-windup) / SP/PV 双输入 PID(输出可缩放,抗积分饱和) |
| Power PID / 动力PID | PID with base power input / 带基础动力PID |
| Clamp / 限制 | Min/Max clamp / 限幅 |
| Map Range / 映射范围 | Range mapping / 范围映射 |
📤 Output / 输出
| Node / 节点 | Description / 说明 |
|---|---|
| Redstone Output / 红石输出 | Write to Redstone Link (0~15) / 写入红石链接 |
| Private Signal Output / 私有信号输出 | Write to named channel / 写入命名通道 |
| Bus Output / 总线输出 | Writes to bus channel / 写入总线通道 |
| Speed Control / 转速控制 | Speed Controller RPM (-256~256) / 转速控制 |
⏱️ Sequential / 时序 (Program Computer only / 仅编程计算机)
| Node / 节点 | Description / 说明 |
|---|---|
| Delay / 延时 | Delay N ticks / 延时N tick |
| Latch / 锁存器 | Set/Reset latch, configurable default / 可配置默认状态 |
| T Flip-Flop / T触发器 | Toggle flip-flop, configurable default / 可配置默认状态 |
| Pulse Extender / 脉冲延长 | Extend input pulse N ticks / 脉冲延长N tick |
| Loop / 循环 | Fire pulse every interval, repeat count times / 循环脉冲 |
| Safety Timer / 保险 | Trigger (rising edge) or held-high input → 2-tick pulse → cooldown; held-high repeats as pulse generator / 触发(上升沿)或持续高电平 → 2 tick 脉冲 → 冷却;持续高电平自动循环(脉冲发生器) |
| Accumulator / 累计器 | Rising-edge step counter / 累计器 |
| Continuous Integrator / 连续积分器 | Continuous integration, configurable limit / 连续积分器 |
🎮 Input / 输入 (Control Seat + Attitude Sensor / 控制座椅+姿态传感器)
| Node / 节点 | Description / 说明 |
|---|---|
| Keyboard Key / 键盘按键 | 58 bindable keys / 58键绑定 |
| Mouse Joystick / 鼠标摇杆 | Dual mode: incremental (mouse delta) / absolute (stick with memory). Toggle in edit panel. / 双模式:增量/绝对值,编辑区切换 |
| View Angle / 视角差 | View angle delta / 视角差 |
| Mouse Button / 鼠标按键 | Left/Right mouse buttons / 鼠标按键 |
| Gamepad Joystick / 手柄摇杆 | Dual stick LX/LY/RX/RY / 双摇杆 |
| Gamepad Button / 手柄按键 | 15 buttons / 15按键 |
| Gamepad Trigger / 手柄扳机 | Analog triggers LT/RT (0~1) / 模拟扳机 |
| World View / 世界视角 | Player absolute world view direction / 玩家绝对视角 |
| Attitude / 姿态 | Block world-space pitch and roll (facing × sub-level rotation) / 方块自身世界姿态俯仰与横滚(朝向 × 子世界旋转) |
| Forward / 前方朝向 | World-space forward yaw/pitch / 结构朝向 |
| Acceleration / 加速度 | Block-local X/Y/Z acceleration (structure motion in block axes) / 方块本地加速度(结构运动按方块朝向分解) |
| Velocity / 速度 | Block-local velocity ×2 m/s (structure motion in block axes) / 方块本地速度(结构运动按方块朝向分解) |
| World Position / 世界坐标 | World position with offset / 世界坐标(可偏移) |
| Target Output / 目标输出 | Radar target X/Y/Z/entityId/distance / 雷达目标 |
🖼️ Display / 显示 (Monitor only / 仅全息显示器)
| Node / 节点 | Description / 说明 |
|---|---|
| Text / 文本 | Text display with color / 文字显示 |
| Data Display / 数值显示 | Float value display / 数值显示 |
| Image / 图像 | 16×16 pixel image, signal-driven position / 像素图片 |
| Image Sequence / 图像序列 | Multi-frame animation, signal-driven frame / 多帧动画 |
📦 Structure / 结构
| Node / 节点 | Description / 说明 |
|---|---|
| Encapsulation / 封装 | Nest sub-graphs inside a node / 嵌套子图 |
| ENCAP_INPUT / 封装输入 | External input pin / 外部输入引脚 |
| ENCAP_OUTPUT / 封装输出 | External output pin / 外部输出引脚 |
🔧 Debug / 调试 (All blocks / 全部方块)
| Node / 节点 | Description / 说明 |
|---|---|
| Comment / 便利贴 | Sticky-note annotation, resizable (80 |
| Signal Generator / 信号发生器 | Test signal source with XY curve preview + Y-axis range label, manual control-point curve or custom f(x) formula, frequency-generate or input-driven output modes, percentile-based robust auto-scale / 测试信号源,XY曲线预览+Y轴范围标注,手动控制点曲线或自定义f(x)公式,频率发生/指定模式输出,百分位数稳健自动缩放 |
| Signal Probe / 信号探针 | Real-time signal monitor with 100-tick trend chart, percentile-based robust auto-scale (p1-p99), freeze/clear / 实时信号监视,100 tick趋势图,百分位数稳健自动缩放(p1-p99),冻结/清除 |
Signal Generator Modes / 信号发生器模式:
| Mode / 模式 | Description / 说明 |
|---|---|
| 🎯 Manual Curve / 手动曲线 | Drag control points on XY chart. Double-click to add, right-click to delete, drag X/Y freely (X clamped between neighbors, server-sorted). Points synced via multiplayer collaboration. / XY图上拖拽控制点。双击添加,右键删除,XY双向自由拖拽(X被相邻点夹持,服务端排序)。多人协作同步。 |
| 📐 Custom f(x) / 自定义公式 | Enter formula expression using variable x (0x(0 |
| 🔄 Frequency Generate / 频率发生 | X auto-advances 0→1 cyclically. Speed control (manual mode only). Current X position shown as sky-blue marker on chart. / X自动0→1循环推进。speed控制速度(仅手动模式)。天蓝色标记线显示当前X位置。 |
| 🎯 Input-Driven / 指定模式 | X set by dragging sky-blue marker line on chart. No EditBox — pure drag interaction. / 拖拽天蓝色标记线设置X值。无输入框,纯拖拽交互。 |
Signal Probe Features / 信号探针功能:
- 100-tick ring buffer trend chart with percentile-based robust auto-scale (p1-p99)
- Percentile filtering replaces fixed ±5 clipping — correctly displays large-range data (e.g. 0~360)
- Right-click: Freeze/Unfreeze, Clear History
- Shows "---" when blueprint not running
🎮 Controls / 操作指南
| Action / 操作 | Input / 按键 |
|---|---|
| Add node menu / 添加节点 | Right-click empty / 右键空白 |
| Two-column layout / 双列布局 | Click the state-label button on the menu title row (1 Col/2 Col), gold = two columns on / 点击菜单标题行右侧状态文字按钮(单列/双列),金色=双列开启 |
| Edit params / 编辑参数 | Left-click → ▶ / 左键→▶ |
| Connect / 连接 | Drag output pin → input pin / 拖拽输出→输入 |
| Delete node / 删除节点 | Hover + X / 悬停+X |
| Delete connection / 删除连线 | TAB + Left-click / TAB+左键点击 |
| Delete selected / 删除选中 | Delete / Backspace |
| Box select / 框选 | TAB + drag / TAB+拖拽 |
| Duplicate / 复制 | Ctrl + D |
| Undo / 撤回 | Ctrl + Z |
| Redo / 重做 | Ctrl + Y |
| Wrap in Comment / 注释包裹 | Select nodes + C / 选中节点+C |
| Edit Comment text / 编辑注释文本 | Double-click comment body / 双击注释节点 |
| Resize Comment / 调整注释大小 | Drag bottom-right corner / 拖动右下角 |
| Scroll Comment / 滚动注释 | Ctrl + Scroll / Ctrl+滚轮 |
| Zoom / 缩放 | Scroll wheel / 滚轮 |
| Pan / 平移 | Right-click drag / 右键拖拽 |
| Open editor (most blocks) / 打开编辑器 | Right-click / 右键 |
| Control Seat — Sit / 乘坐 | Right-click (empty hand) / 右键(空手) |
| Control Seat/Radar — Editor / 编辑器 | Shift + Right-click / Shift+右键 |
| Control Seat — Dismount / 下马 | ~ |
| Control Seat — Switch mode / 切换模式 | TAB |
| Control Seat — Release mouse / 释放鼠标 | ESC |
| Signal Gen — Add control point / 添加控制点 | Double-click XY chart / 双击XY图 |
| Signal Gen — Delete control point / 删除控制点 | Right-click control point / 右键控制点 |
| Signal Gen — Drag control point / 拖拽控制点 | Left-drag (X clamped, Y free) / 左键拖拽 |
| Signal Gen — Drag X marker / 拖拽X标记 | Left-drag sky-blue line (input mode) / 左键拖拽天蓝色线 |
| Signal Gen — Switch mode / 切换模式 | Click toggle button (confirm with second click) / 点击切换按钮(二次点击确认) |
| Probe — Freeze/Unfreeze / 冻结解冻 | Double-click probe node / 双击探针节点 |
| Probe — Clear/Clear History / 清除历史 | Right-click probe node / 右键探针节点 |
| Bookmark — Open panel / 打开书签面板 | Click ★ bottom-right / 点击右下角★ |
| Bookmark — Add / 添加书签 | [+] in panel or Ctrl+M / 面板内[+]或Ctrl+M |
| Bookmark — Rename / 重命名 | Click ✎ on bookmark row / 点击书签行✎ |
| Bookmark — Delete / 删除 | Click × on bookmark row / 点击书签行× |
| Bookmark — Jump / 跳转 | Click → or name / 点击→或名称 |
| Bookmark — Reorder / 拖拽排序 | Drag name area to new position / 拖拽名称区域到新位置 |
| Bookmark — Reset view / 重置视角 | [↺] in panel or Home key / 面板[↺]或Home键 |
🔄 Sable Physics Integration / Sable 物理集成
Deep integration with Sable physics engine for rotating structures. / 与Sable物理引擎深度集成,支持旋转结构。
| Block / 方块 | Feature / 功能 |
|---|---|
| Control Seat / 控制座椅 | Entity yaw tracks sub-level rotation / 实体yaw追踪子世界 |
| Attitude Sensor / 姿态传感器 | Read logicalPose() quaternion / 读取姿态四元数 |
Thread safe / 线程安全: Shared fields
volatile. Without Sable / 无Sable: Control Seat fully functional, Sensor outputs 0 / 控制座椅完全可用,传感器输出0
💾 Schematic Support / 蓝图兼容
All 10 blocks support Create's Schematicannon — graphs and state fully preserved. / 全部十种方块支持蓝图大炮,图与状态完整保留。
Uses Create's IMergeableBE + SafeNbtWriter / 采用 Create 官方接口
📦 Recipes / 合成配方
| Block / 方块 | Materials / 材料 |
|---|---|
| 🖥️ Monitor / 全息显示器 | Redstone Link×2 + Precision Mechanism + Glass Pane×2 + Brass Casing + Glowstone Dust×2 |
| 🖥️ Blueprint / 蓝图计算机 | Redstone Link×2 + Precision Mechanism + Glass Pane×2 + Repeater + Comparator + Brass Casing×2 |
| ⚡ Speed Proxy / 转速代理 | Brass Ingot×4 + Cogwheel + Glass Pane×2 + Comparator + Andesite Casing |
| 🔌 Program / 编程计算机 | Andesite Casing×4 + Repeater + Glass Pane×2 + Comparator + Andesite Alloy |
| 🪑 Control Seat / 控制座椅 | Heavy Weighted Pressure Plate + Iron Ingot×2 + Brass Casing + Redstone + Redstone Link×4 |
| 📐 Attitude Sensor / 姿态传感器 | Iron Ingot×6 + Repeater + Comparator + Brass Casing×2 |
| 📡 Radar / 雷达 | Monitor×2 + Iron Ingot×4 + Brass Casing + Redstone Block×2 |
| 📱 Portable Terminal / 便携终端 | Redstone Link×4 + Blueprint Computer + Glass Pane×4 |
| 🎛️ Kinetic Gauge / 动力传感器 | Iron Ingot×4 + Shaft×4 + Brass Casing |
⚙️ Block Properties / 方块属性
| Property / 属性 | Value / 值 |
|---|---|
| Hardness / 硬度 | 1.0 (hand breakable / 空手可破坏) |
| Hand break / 空手破坏 | Drops without NBT / 掉落无NBT |
| Wrench right-click / 扳手右键 | Rotate FACING / 旋转方向 |
| Wrench Shift+right-click / 扳手Shift+右键 | Pick up with full NBT / 收回保留NBT |
| 🎛️ Kinetic Gauge wrench / 动力传感器扳手 | Shaft end face + display side: cycle the display 90° around the shaft; the other two faces: rigid rotate (shaft re-points) / 轴端面+显示面:显示绕轴 90° 循环;其余两面:整表旋转(轴换向) |
🔧 Technical Highlights / 技术亮点
| Feature / 特性 | Description / 说明 |
|---|---|
| 👥 Multiplayer Collaboration / 多人协作 | Real-time editing, cursor tracking, node lock / 实时编辑、光标追踪、节点锁 |
| ⚡ Server-Authoritative Eval / 服务端权威评估 | Client receives EvalSnapshot — no local evaluator / 客户端接收快照,无本地评估器 |
| ⚡ Topological Sort Eval / 拓扑排序求值 | O(1) input query cache / O(1) 输入查询缓存 |
| 🚀 GC-Friendly / GC友好 | Reused evaluator instances / 重用求值器 |
| 🔄 Signal Bus / 信号总线 | Global named-channel communication / 全局命名通道通信 |
| 🧹 PID Anti-Windup / PID抗饱和 | Integral capping / 积分上限钳制 |
| 🛡️ Cycle Detection / 环检测 | Compile-time circular dependency check / 编译时循环引用检测 |
| 🎮 GLFW Raw Input / GLFW原始输入 | Bypass Minecraft keybinding system / 绕过MC键位系统 |
| 🔄 Sable Integration / Sable集成 | BlockEntitySubLevelActor sub-level pose reading / 子世界姿态读取 |
📜 Changelog / 更新日志
完整变更日志已拆分至 CHANGELOG.md —— 每个版本一个 <details> 块。
The full changelog now lives in CHANGELOG.md — one <details> block per release.
| Version | 标题 / Title |
|---|---|
| v1.2.5.1 | 动力传感器(kinetic_gauge,Create 表同款 3 轴放置 · STRESS/RPM 节点 · 蓝屏显示)· 编辑器输入焦点与选中高亮修复 · GUI 巨型文件拆分(HUD 裁剪数学 / 显示编辑器 / 设置界面 tab) |
| v1.2.5 | 公式语言升级:控制流 + vec3 + 预算池 / GUI 架构迁移 / 像素编辑器 / 可编程变速箱 |
| v1.2.4.1 | 回归审计 · 总线系统 · 封装状态 · 公式一致性 · Sable 加固 |
| v1.2.4 | 多人协作 + 调试工具链 + 公式编辑器体验 |
更早版本(v1.2.3 及以前)见 CHANGELOG.md。
Older releases (v1.2.3 and earlier): see CHANGELOG.md.
❓ FAQ / 常见问题
Node editor laggy? / 节点编辑器卡顿?
Too many nodes or complex PID. Keep PIDs reasonable. / 节点过多或PID复杂,单计算机PID不宜超过5-6个。Speed Proxy not working? / 转速代理不工作?
Place directly adjacent to a Speed Controller. / 放置在转速控制器相邻面。State lost after schematic? / 蓝图放置后状态丢失?
Use Create 6.0.10+. Full NBT interfaces registered. / 确保使用Create 6.0.10+。Can computers communicate? / 计算机可以通信吗?
Yes — Private Signal I/O (named channels) or BUS_IN/BUS_OUT (banded). / 可以——私有信号I/O或BUS总线。📥 Installation / 安装
| Dependency / 依赖 | Version / 版本 |
|---|---|
| Minecraft | 1.21.1 |
| NeoForge | 21.1.233+ |
| Create | 6.0.10+ |
Sable is optional / Sable 为可选
- Install NeoForge + Create / 安装 NeoForge + Create
- Place
.jarinmodsfolder / 将.jar放入mods - Launch! / 启动!
🌐 Links / 链接
- GitHub: github.com/y15173334444/create-schematic-compute
- Modrinth: modrinth.com/mod/create-schematic-compute
- License / 许可证: MIT © 2026 StarryNight_Luo
⭐ If you enjoy this mod, star us on GitHub! / 喜欢请在GitHub点⭐!
Unleash Create's potential with visual programming! / 用可视化编程释放机械动力的潜力!🚀